VTOL Manuals & Technical Documents
Search aircraft manuals, ArduPilot references, flight-controller guides, ESC documentation, radio setup information, sensor manuals, GPS specifications, and hardware standards.
What are you working on?
Jump straight to the documents for a common task.
Find a manual
Search by title, vendor, category, version, or keyword — then narrow by category.
Showing all 54 documents
N7 Autopilot User Manual (ArduPilot) v1.0
Full setup and configuration guide for the SIYI N7 autopilot running ArduPilot. Covers hardware wiring, IMU calibration, GPS setup, Mission Planner integration, and firmware update procedure.
Pixhawk Autopilot Bus Standard (DS-010)
Official Pixhawk Autopilot Bus (PAB) hardware standard. Defines the connector pinout, mechanical form factor, power domains, and signal requirements for PAB-compatible carrier boards and modules.
Pixhawk Autopilot v6X Standard (DS-012)
Hardware specification standard for the Pixhawk v6X autopilot module. Covers mechanical dimensions, electrical interfaces, IO mapping, connector layout, and compliance requirements.
KDE CAN ESCs / Pixhawk QuickStart
QuickStart guide for integrating KDE Direct CAN ESCs with a Pixhawk flight controller over DroneCAN/UAVCAN. Covers firmware setup, node ID assignment, parameter configuration, and ArduPilot settings.
HEEWING F405 Flight Controller Manual
User manual for the HEEWING F405 flight controller. Covers pinout, wiring diagrams, UART assignments, ELRS/receiver setup, firmware flashing, and INAV/ArduPilot configuration for VTOL fixed-wing aircraft.
SpeedyBee F405 Mini BLS 35A Stack — User Manual
User manual for the SpeedyBee F405 Mini + BLS 35A 4-in-1 ESC stack. Covers STM32F405 pinout, Bluetooth app setup, receiver wiring (SBUS/ELRS), DJI Air Unit connection, and ESC Configurator calibration.
SpeedyBee F405 Wing App Manual
Manual for the SpeedyBee F405 Wing flight controller and its companion mobile app. Covers UART mapping, servo outputs, Bluetooth parameter editing, receiver setup, and fixed-wing INAV configuration.
CUAV CAN/DroneCAN Power Module Manual
Manual for the CUAV CAN/DroneCAN PMU power module. Covers CAN bus wiring, node configuration, voltage/current sensing calibration, ArduPilot battery monitor parameters, and failsafe setup.
CUAV V5 Nano Manual
Complete user guide for the CUAV V5 Nano autopilot. Covers hardware interfaces, GPS and compass wiring, telemetry setup, power input, and ArduPilot/PX4 configuration for lightweight VTOL and fixed-wing builds.
CUAV V5 Plus Manual
User guide for the CUAV V5 Plus autopilot. Details full-size Pixhawk-form connector pinout, redundant IMU architecture, CAN bus ports, power brick setup, and ArduPilot/PX4 wiring for VTOL platforms.
Marvelmind Navigation System Manual
Operating manual for the Marvelmind indoor ultrasonic positioning system. Covers hardware setup, beacon placement, hedgehog modem wiring, ArduPilot GPS_TYPE configuration, and position accuracy tuning.
LOCOSYS HAWK R1/R2 Datasheet
Technical datasheet for the LOCOSYS HAWK R1 and R2 RTK GNSS receivers. Covers L1/L5 band reception, RTK accuracy, serial interface, NMEA output, ArduPilot GPS_TYPE settings, and mounting recommendations.
Lightware SF02 Laser Rangefinder Manual
User manual for the Lightware SF02 laser rangefinder. Covers serial and I2C interfaces, range and accuracy specs, ArduPilot RNGFND_TYPE parameter, mounting orientation, and terrain-following configuration.
SPRacing H7 RF Manual
Reference manual for the SPRacing H7 RF flight controller. Covers STM32H7 processor features, pinout, receiver setup (ExpressLRS/FrSky), blackbox logging, and Betaflight/INAV firmware configuration.
DroneCAN QuickStart Guide v1.0.3
QuickStart guide for DroneCAN (formerly UAVCAN) network setup. Covers bus topology, termination resistors, node ID assignment, ArduPilot CAN_DRIVER settings, and connecting CAN ESCs, GPS, and power modules.
Zubax Sapog v2 Reference Manual
Reference manual for the Zubax Sapog v2 sensorless PMSM/BLDC motor controller firmware. Covers UAVCAN/DroneCAN interface, RCPWM input, control algorithm parameters, and CLI configuration.
Zubax Orel 20 Datasheet
Datasheet for the Zubax Orel 20 DroneCAN/UAVCAN ESC. Covers electrical specifications, CAN bus integration, thrust/current curves, cooling requirements, and ArduPilot motor mapping for multirotor and VTOL.
TOFSense-F Datasheet V2.0
Datasheet for the Nooploop TOFSense-F time-of-flight ranging sensor. Covers detection range, field of view, UART/I2C interface, ArduPilot RNGFND_TYPE setup, and mounting considerations for altitude hold.
TOFSense Datasheet V3.0
Datasheet for the Nooploop TOFSense V3.0 ToF sensor. Covers updated range performance, serial protocol, multi-sensor avoidance of cross-talk, ArduPilot RNGFND_TYPE parameters, and indoor altitude control.
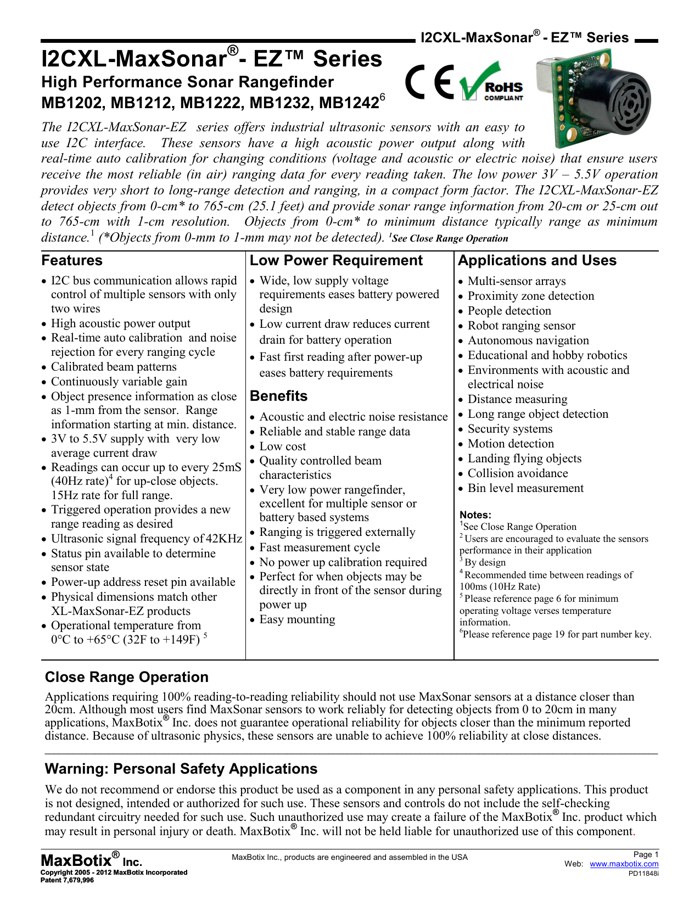
MaxBotix I2CXL-MaxSonar-EZ Datasheet
Datasheet for the MaxBotix I2CXL-MaxSonar-EZ ultrasonic rangefinder series. Covers I2C address, ranging commands, beam pattern, detection zone, ArduPilot RNGFND_TYPE config, and mounting for terrain following.
Lightware SF10 Laser Altimeter Manual
User manual for the Lightware SF10 series laser altimeter. Covers long-range altitude measurement, serial and I2C protocols, ArduPilot RNGFND_TYPE and RNGFND_MAX_CM parameters, and precision landing support.
Futaba S-Link Manual
Manual for the Futaba S-Link wireless trainer and telemetry system. Covers S.BUS output to ArduPilot RC_PROTOCOLS, telemetry sensor wiring, channel mapping, and failsafe configuration for VTOL RC systems.
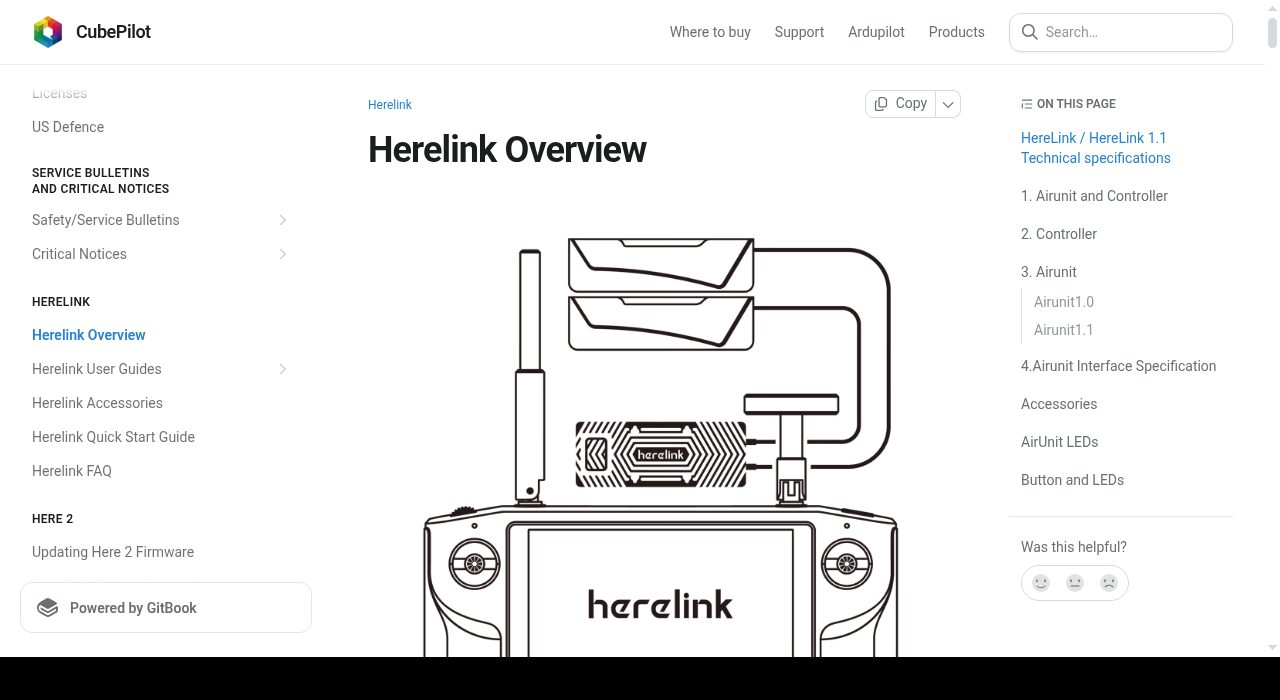
Herelink Overview
Technical overview and full specifications of the Herelink integrated RC controller, ground station, and 2.4 GHz HD video/telemetry link system with 20 km range.
Herelink User Guides Index
Index of all Herelink user guides: assembly, firmware upgrade, pairing, button configuration, wireless communication, video sharing, and more.
Herelink Assembly and Connection
Step-by-step guide for assembling the Herelink controller antenna, mounting and cabling the air unit, and connecting it to the flight controller SBUS, UART, and HDMI inputs.
Herelink Firmware Upgrade Guide
Instructions for updating Herelink controller and air unit firmware via PC flasher tool or OTA WiFi update, including activation key setup and driver troubleshooting.
Herelink Pairing, RC Calibration & Setup
One-time setup procedure for Herelink: hardware wheel and joystick calibration, SBUS output calibration, RC transmitter mode selection, and dual-control trainer mode configuration.
Herelink Configure Modes & MAVLink Buttons
How to configure Herelink buttons A–D, Cam, and Home to send MAVLink commands (flight mode changes, arm/disarm, servo outputs, camera control) via Solex TX and QGroundControl.
Herelink Configure SBUS Buttons & Wheel
Configure Herelink SBUS channel outputs for buttons A–D, Cam, and hardware wheel; covers toggle, momentary, and multi-mode button types on dual SBUS buses.
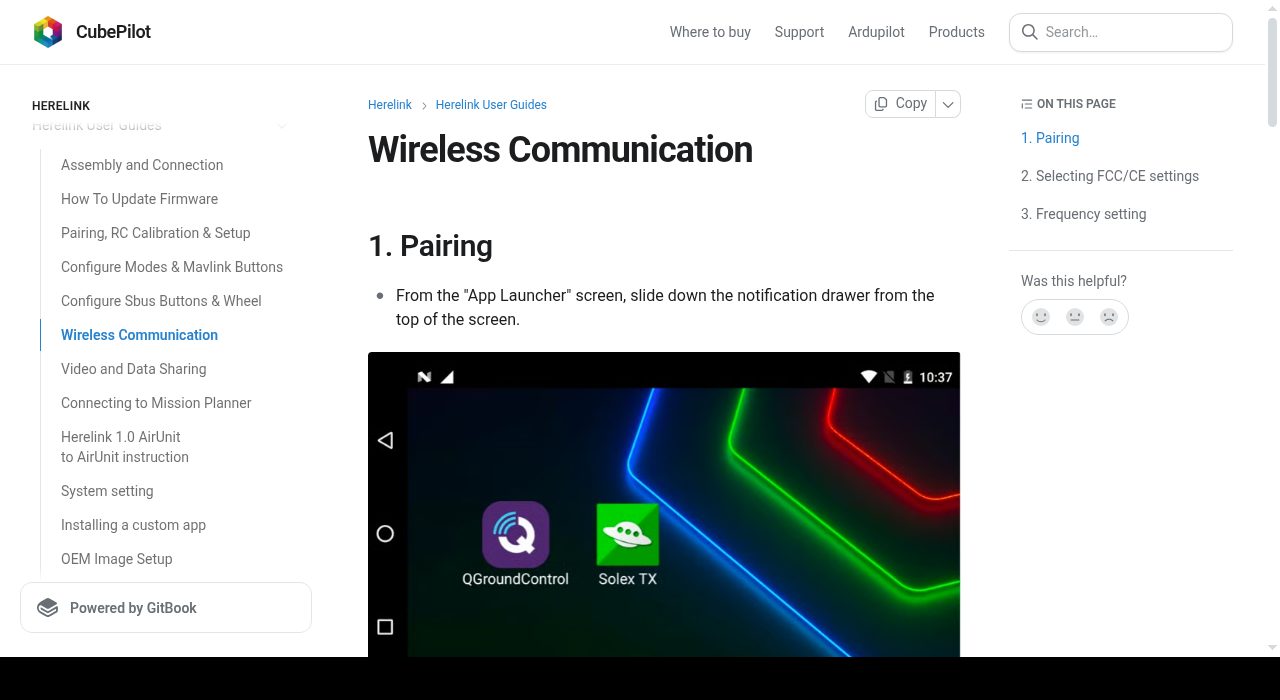
Herelink Wireless Communication
Pairing procedure, FCC/CE region selection, frequency band configuration, bandwidth settings, and frequency hopping setup for the Herelink 2.4 GHz link.
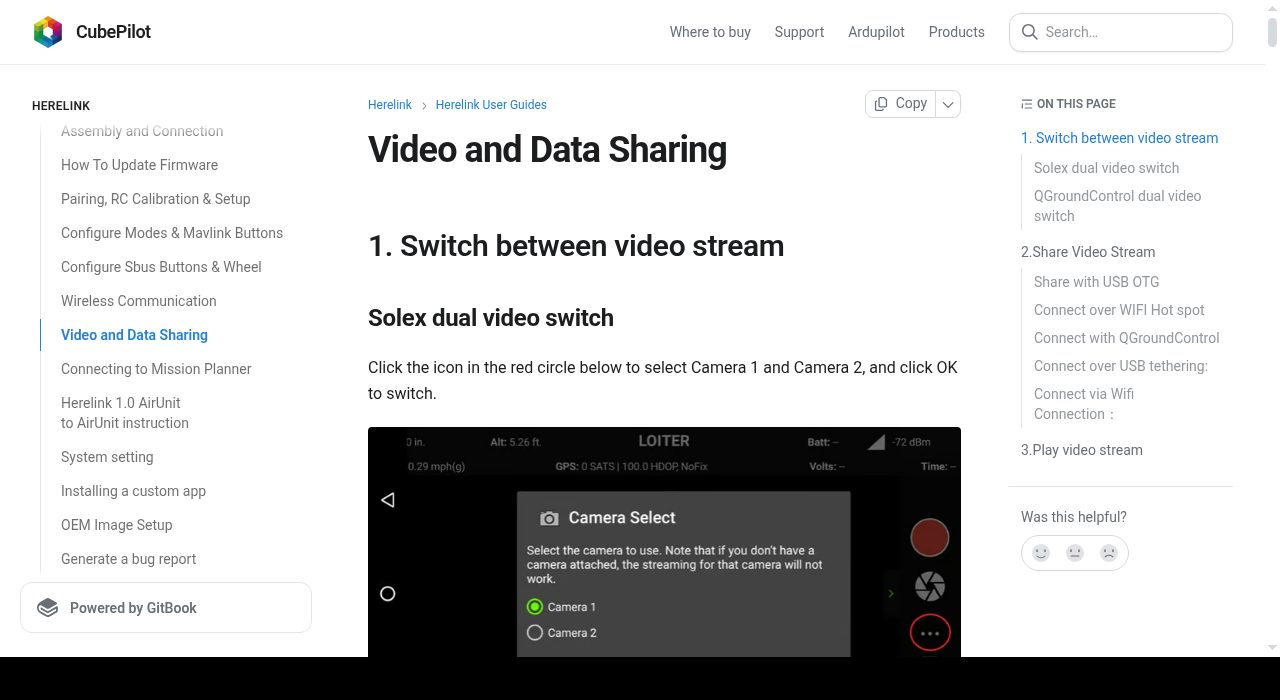
Herelink Video and Data Sharing
Sharing Herelink HD video and MAVLink telemetry over WiFi hotspot, USB tethering, and Ethernet; RTSP stream URLs and connection steps for Mission Planner, QGC, and VLC.
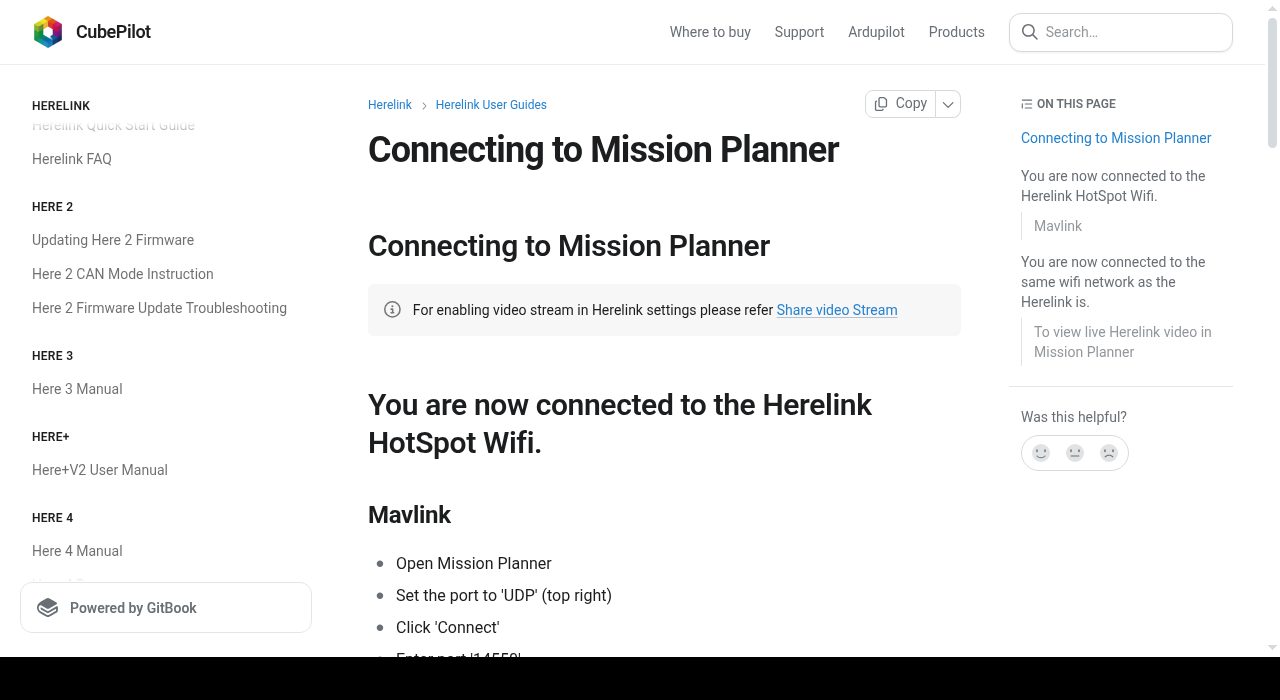
Herelink Connect to Mission Planner
Connection procedures for Mission Planner via Herelink WiFi hotspot and other interfaces; includes MAVLink UDP/UDPCL port settings and live video stream setup.
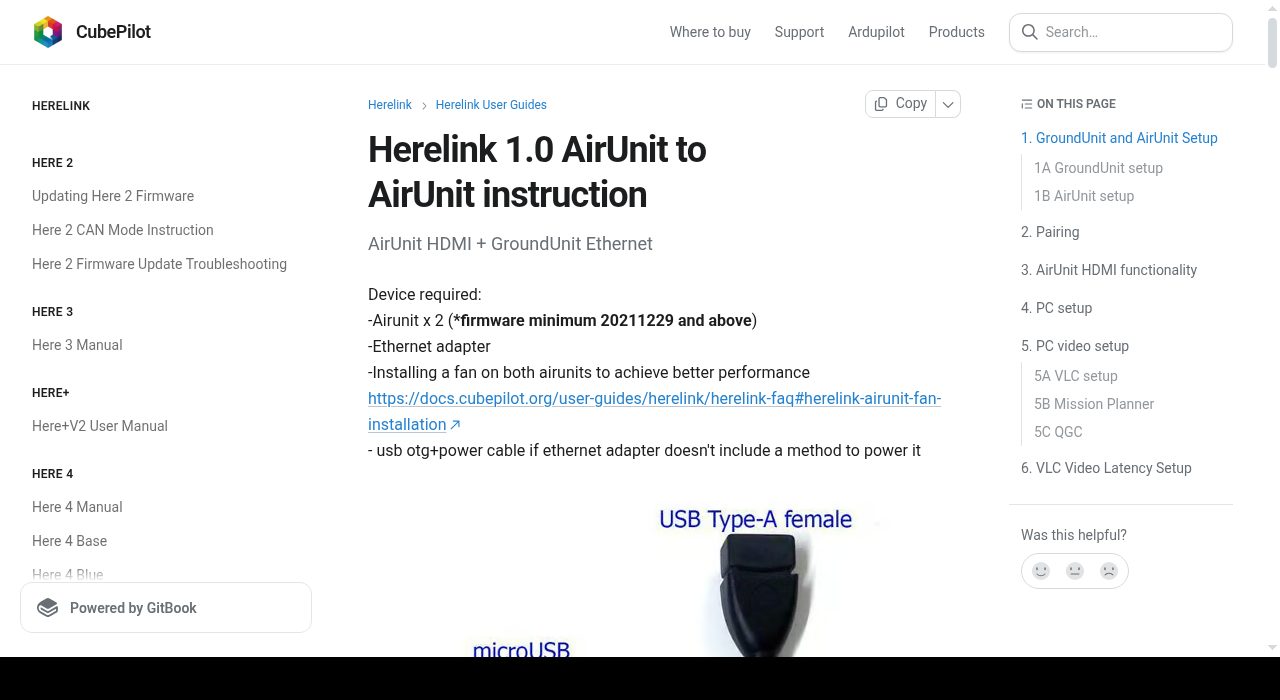
Herelink 1.0 AirUnit-to-AirUnit Instruction
Setup guide for using two Herelink AirUnits in a ground-unit / air-unit configuration via Ethernet, with RTSP video and MAVLink over a local network.
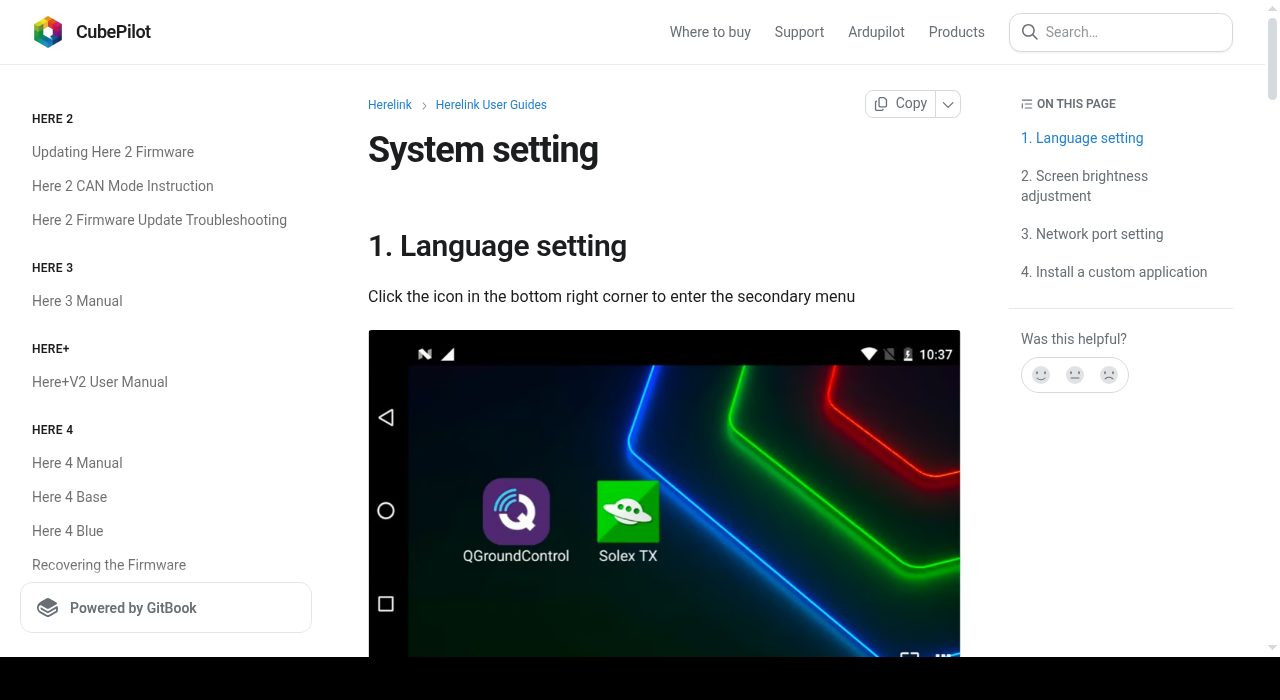
Herelink System Settings
System configuration for the Herelink controller: language settings, screen brightness, network port IP addressing, and ADB-based custom app installation.
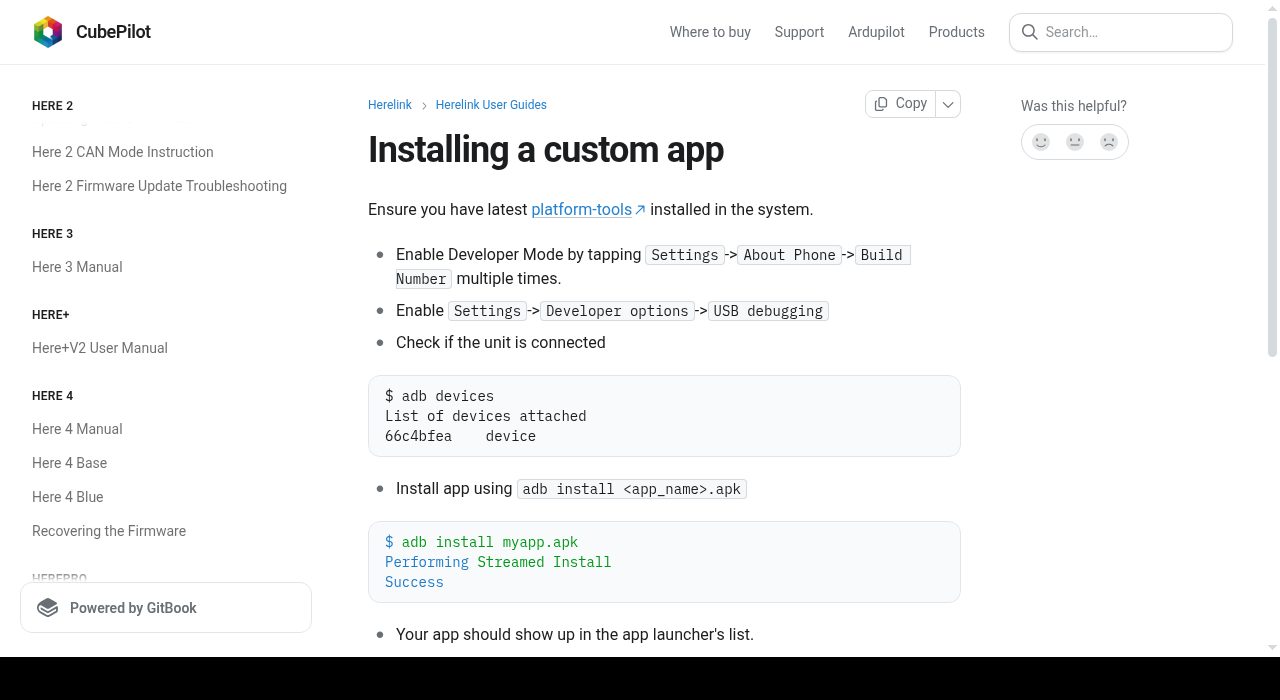
Herelink Installing a Custom App
How to sideload custom Android APK applications onto the Herelink controller using ADB; includes enabling developer mode and USB debugging.
Herelink OEM Image Setup
Guide for OEMs to create custom firmware images for the Herelink air unit and remote unit: mounting ext4 images, modifying config files, replacing apps, and flashing via fastboot.
Herelink Generate a Bug Report
Step-by-step procedure for generating and extracting an ADB bug report from the Herelink controller for submission to CubePilot support.
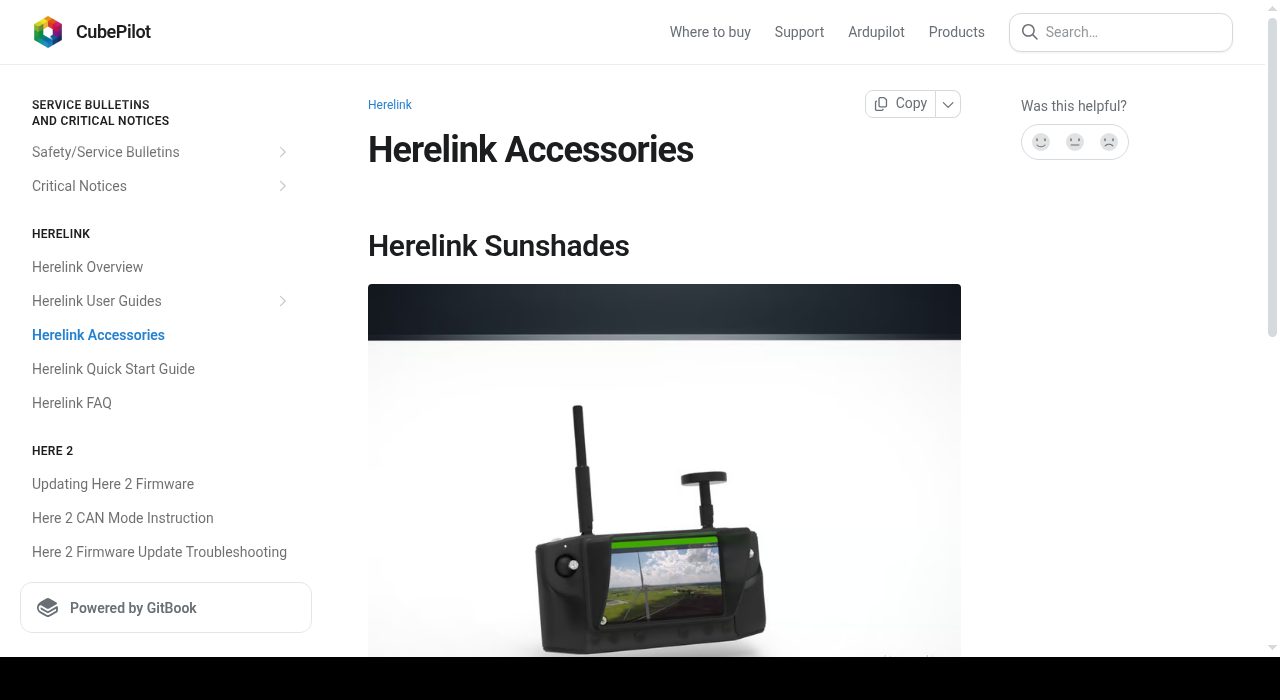
Herelink Accessories
Printable 3D sunshade designs for the Herelink controller screen: two versions available (basic and self-tightening) for outdoor use in bright conditions.
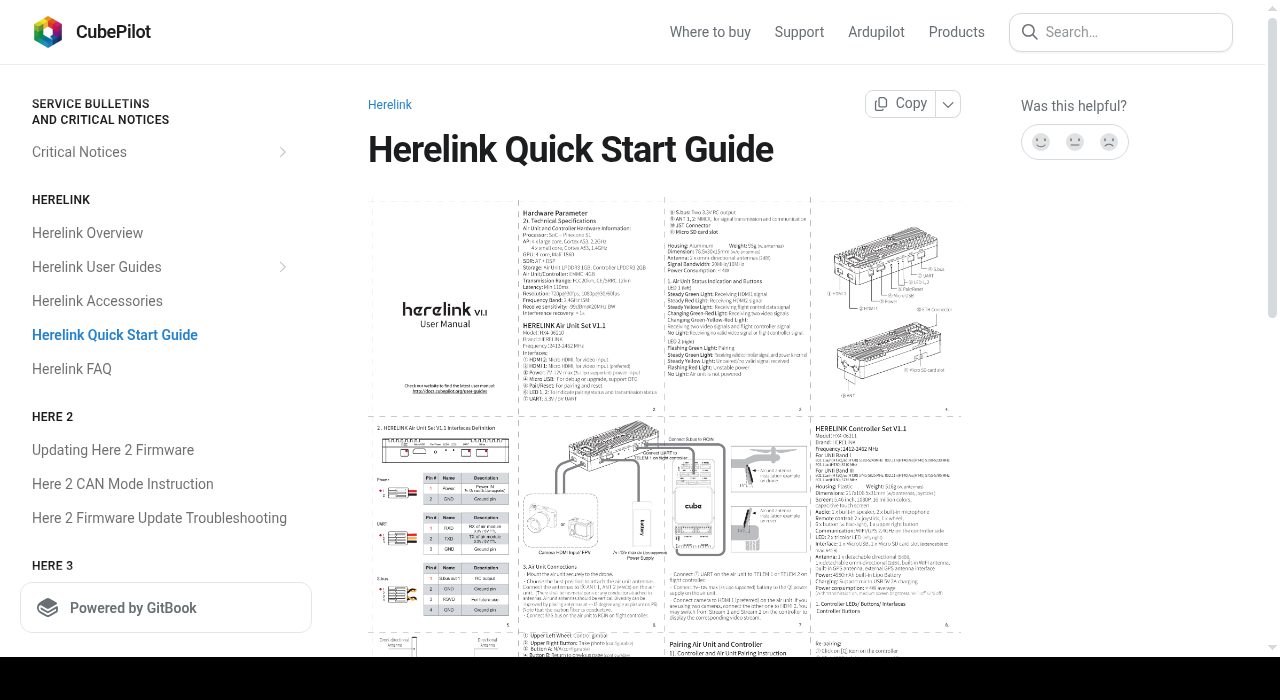
Herelink Quick Start Guide
Quick start reference for the Herelink integrated RC controller and video/telemetry link; covers initial setup essentials for new users.
Herelink FAQ
Frequently asked questions for Herelink: registration failures, compatible cameras, Solex autostart, video/dual-stream setup, Ethernet passthrough, AES encryption, and power output by region.
Here 2 Firmware Update Guide
Step-by-step guide for updating the Here 2 GPS firmware and bootloader using Mission Planner's SLCAN/DroneCAN interface with a Cube autopilot.
Here 2 CAN Mode Instruction
How to configure the Here 2 GPS in CAN/DroneCAN mode with node ID allocation, compass and barometer setup, and parameter configuration for ArduPilot and PX4.
Here 2 Firmware Update Troubleshooting
Troubleshooting guide for Here 2 firmware update issues: SLCAN detection failures, solid green LEDs, boot delay fixes, and CAN port labelling errors on early carrier boards.
Here 3 / Here 3+ Manual
Complete manual for the Here 3 and Here 3+ DroneCAN RTK GPS modules: hardware specs, ArduPilot and PX4 setup, RTK base/rover operation, CAN node configuration, firmware update, and LED codes.
Here+ V2 User Manual
User manual for the Here+ V1 and V2 RTK GPS kit: hardware specs, rover and base connection, antenna placement, Mission Planner RTK setup, u-center firmware update, and advanced configuration.
Here 4 Manual
Full manual for the Here 4 dual-band RTK GPS module: F9P specifications, DroneCAN 8 Mbit setup, ArduPilot and PX4 parameters, RTK operation, moving baseline, and installing ArduPilot firmware.
Here 4 Base Station Manual
Setup and operation guide for the Here 4 Base RTK station: dual-band F9P specifications, Mission Planner survey-in procedure, fixed-mode configuration, and multi-rover deployment.
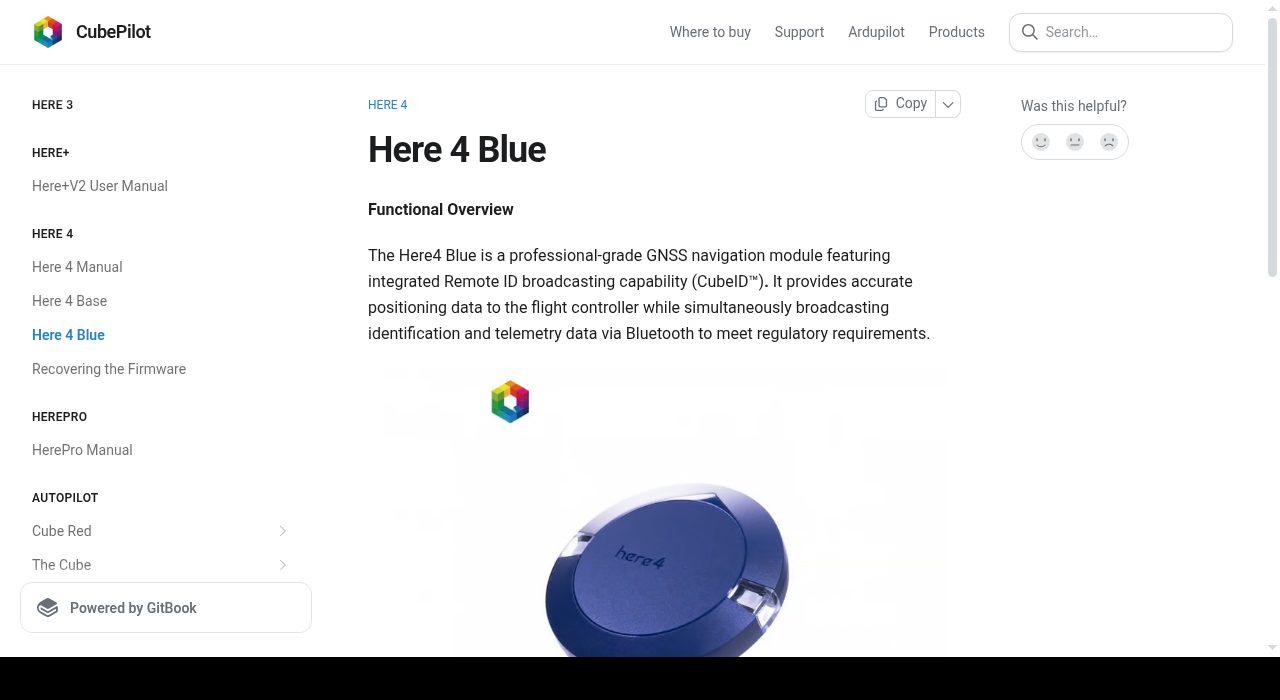
Here 4 Blue Manual
Overview of the Here 4 Blue: NDAA-compliant dual-band RTK GPS with integrated CubeID Remote ID broadcasting via Bluetooth 5.2, designed for government and enterprise UXV applications.
Here 4 Firmware Recovery
Procedure for recovering the Here 4 firmware via SWD port using J-Link or ST-Link when normal firmware updates fail or solid white LEDs appear.
HerePro Manual
Complete manual for HerePro high-precision multi-band RTK GPS: F9P specs, DroneCAN CAN FD, ArduPilot and PX4 setup, GPS yaw, LED Lua scripting, RTK base/rover operation, and firmware update.
Cube Red Autopilot
Overview of the Cube Red dual-FMU autopilot: redundant dual-core processors running independent ArduPilot instances, Ethernet interface, and extended external flash memory.
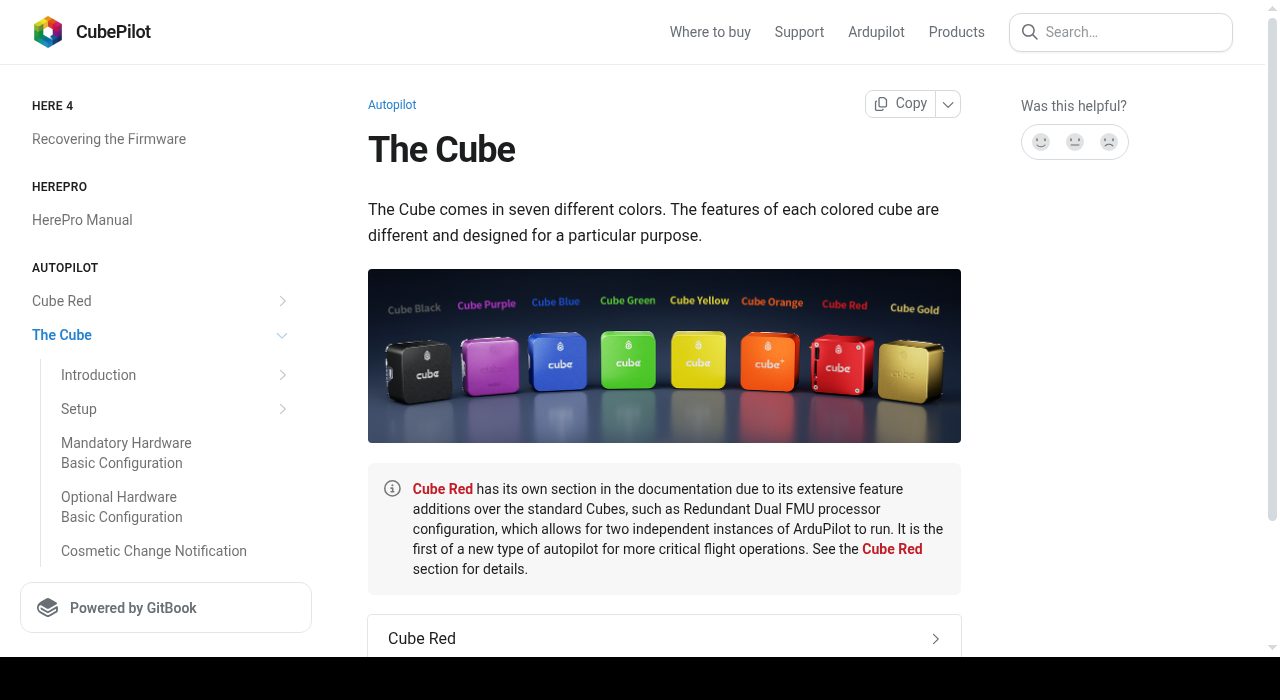
The Cube Autopilot Overview
Overview of the Cube autopilot family (Black, Blue, Orange, Purple, Yellow, Red) and their differences; includes a reference to the Cube Red section for its advanced dual-FMU architecture.
Cube First Flight Guide
Pre-arm safety checks, LED indicator meanings, arming procedures (RC and Mission Planner), and first-flight preparation steps for Cube autopilot-powered vehicles.
The Cube FAQ
Frequently asked questions for the Cube autopilot: Windows driver reset, USB connection troubleshooting for dual-endpoint Cube models, and Mission Planner COM port verification.
No documents match your search
Try a different keyword or clear the filters to see everything.